Capstone · Robotics
6-DOF Robotic Arm
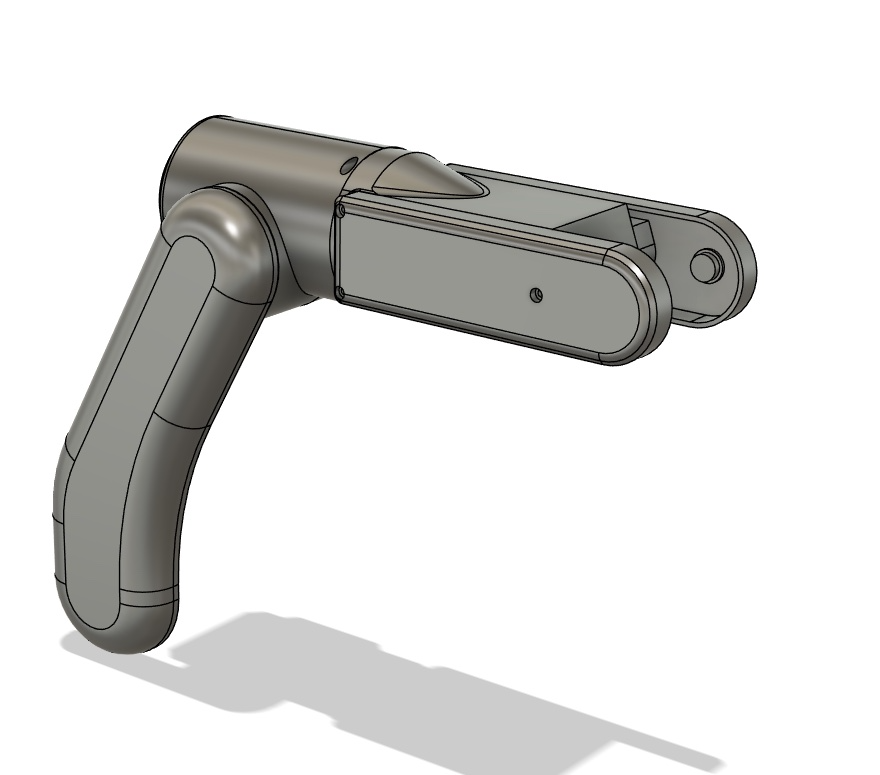
A team capstone developing an affordable six-axis robotic arm. My contribution focuses on software development and system integration: connecting a custom teach-pendant interface to embedded motor control.
Demonstrated: UI-to-microcontroller communication, servo position commands, and adjustable motion timing in the first-phase prototype.
Phase 2 · Project plan · September–December 2026
MASQ V1.0 — Assembly, integration & validation
The Phase 2 plan develops a five-axis arm with CAN-based communication and teach-and-repeat operation. It covers mechanical and electrical completion, integration with the existing software, joint calibration, and testing.
My planned responsibilities: requirements review, parts procurement, and BOM finalization, alongside team testing and the final presentation.
Phase 1: my contribution, design decisions & results
My contribution
I contributed to software development and system integration, working on the connection between the teach-pendant interface, backend communication, and embedded control. Marcus J. Cameron focused on mechanical design and fabrication; Quinn Sheppard focused on electrical design and system architecture.
The integration challenge
The interface needed to send clear motor commands while leaving room for more joints and motion parameters. A simple ID:position text format was considered, but structured JSON made the commands easier to extend. A Flask web interface sends HTTP requests to a Python bridge, which formats commands for the Arduino over USB serial.
What the prototype demonstrated
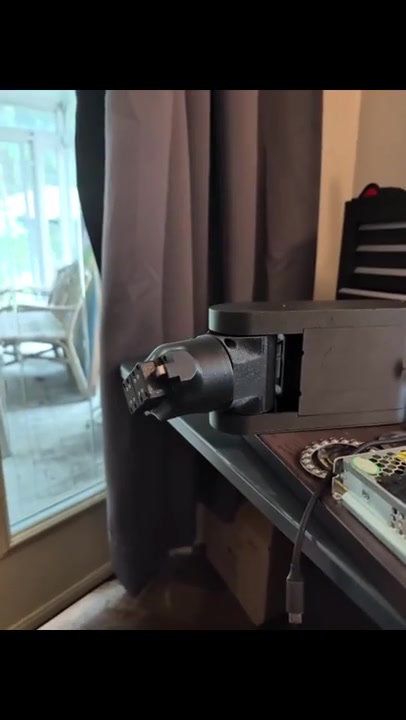
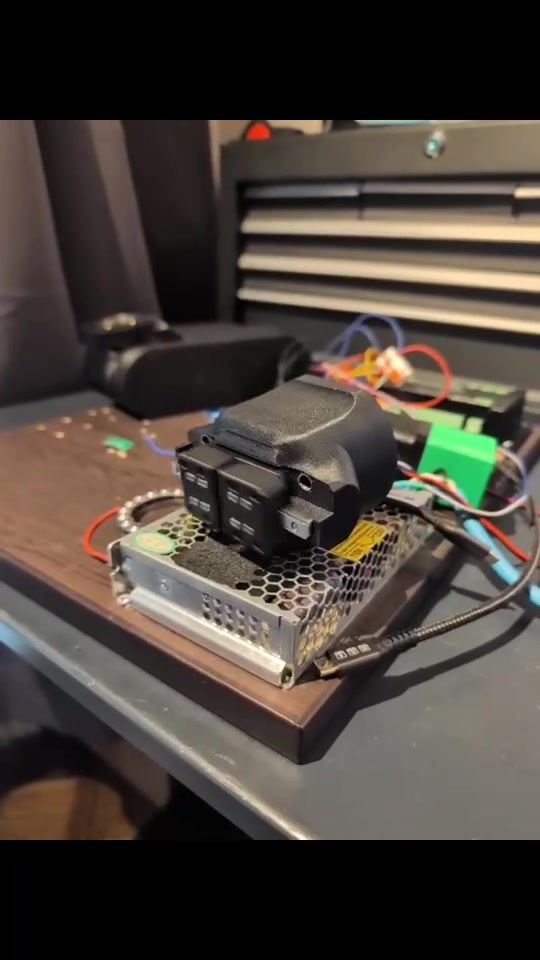
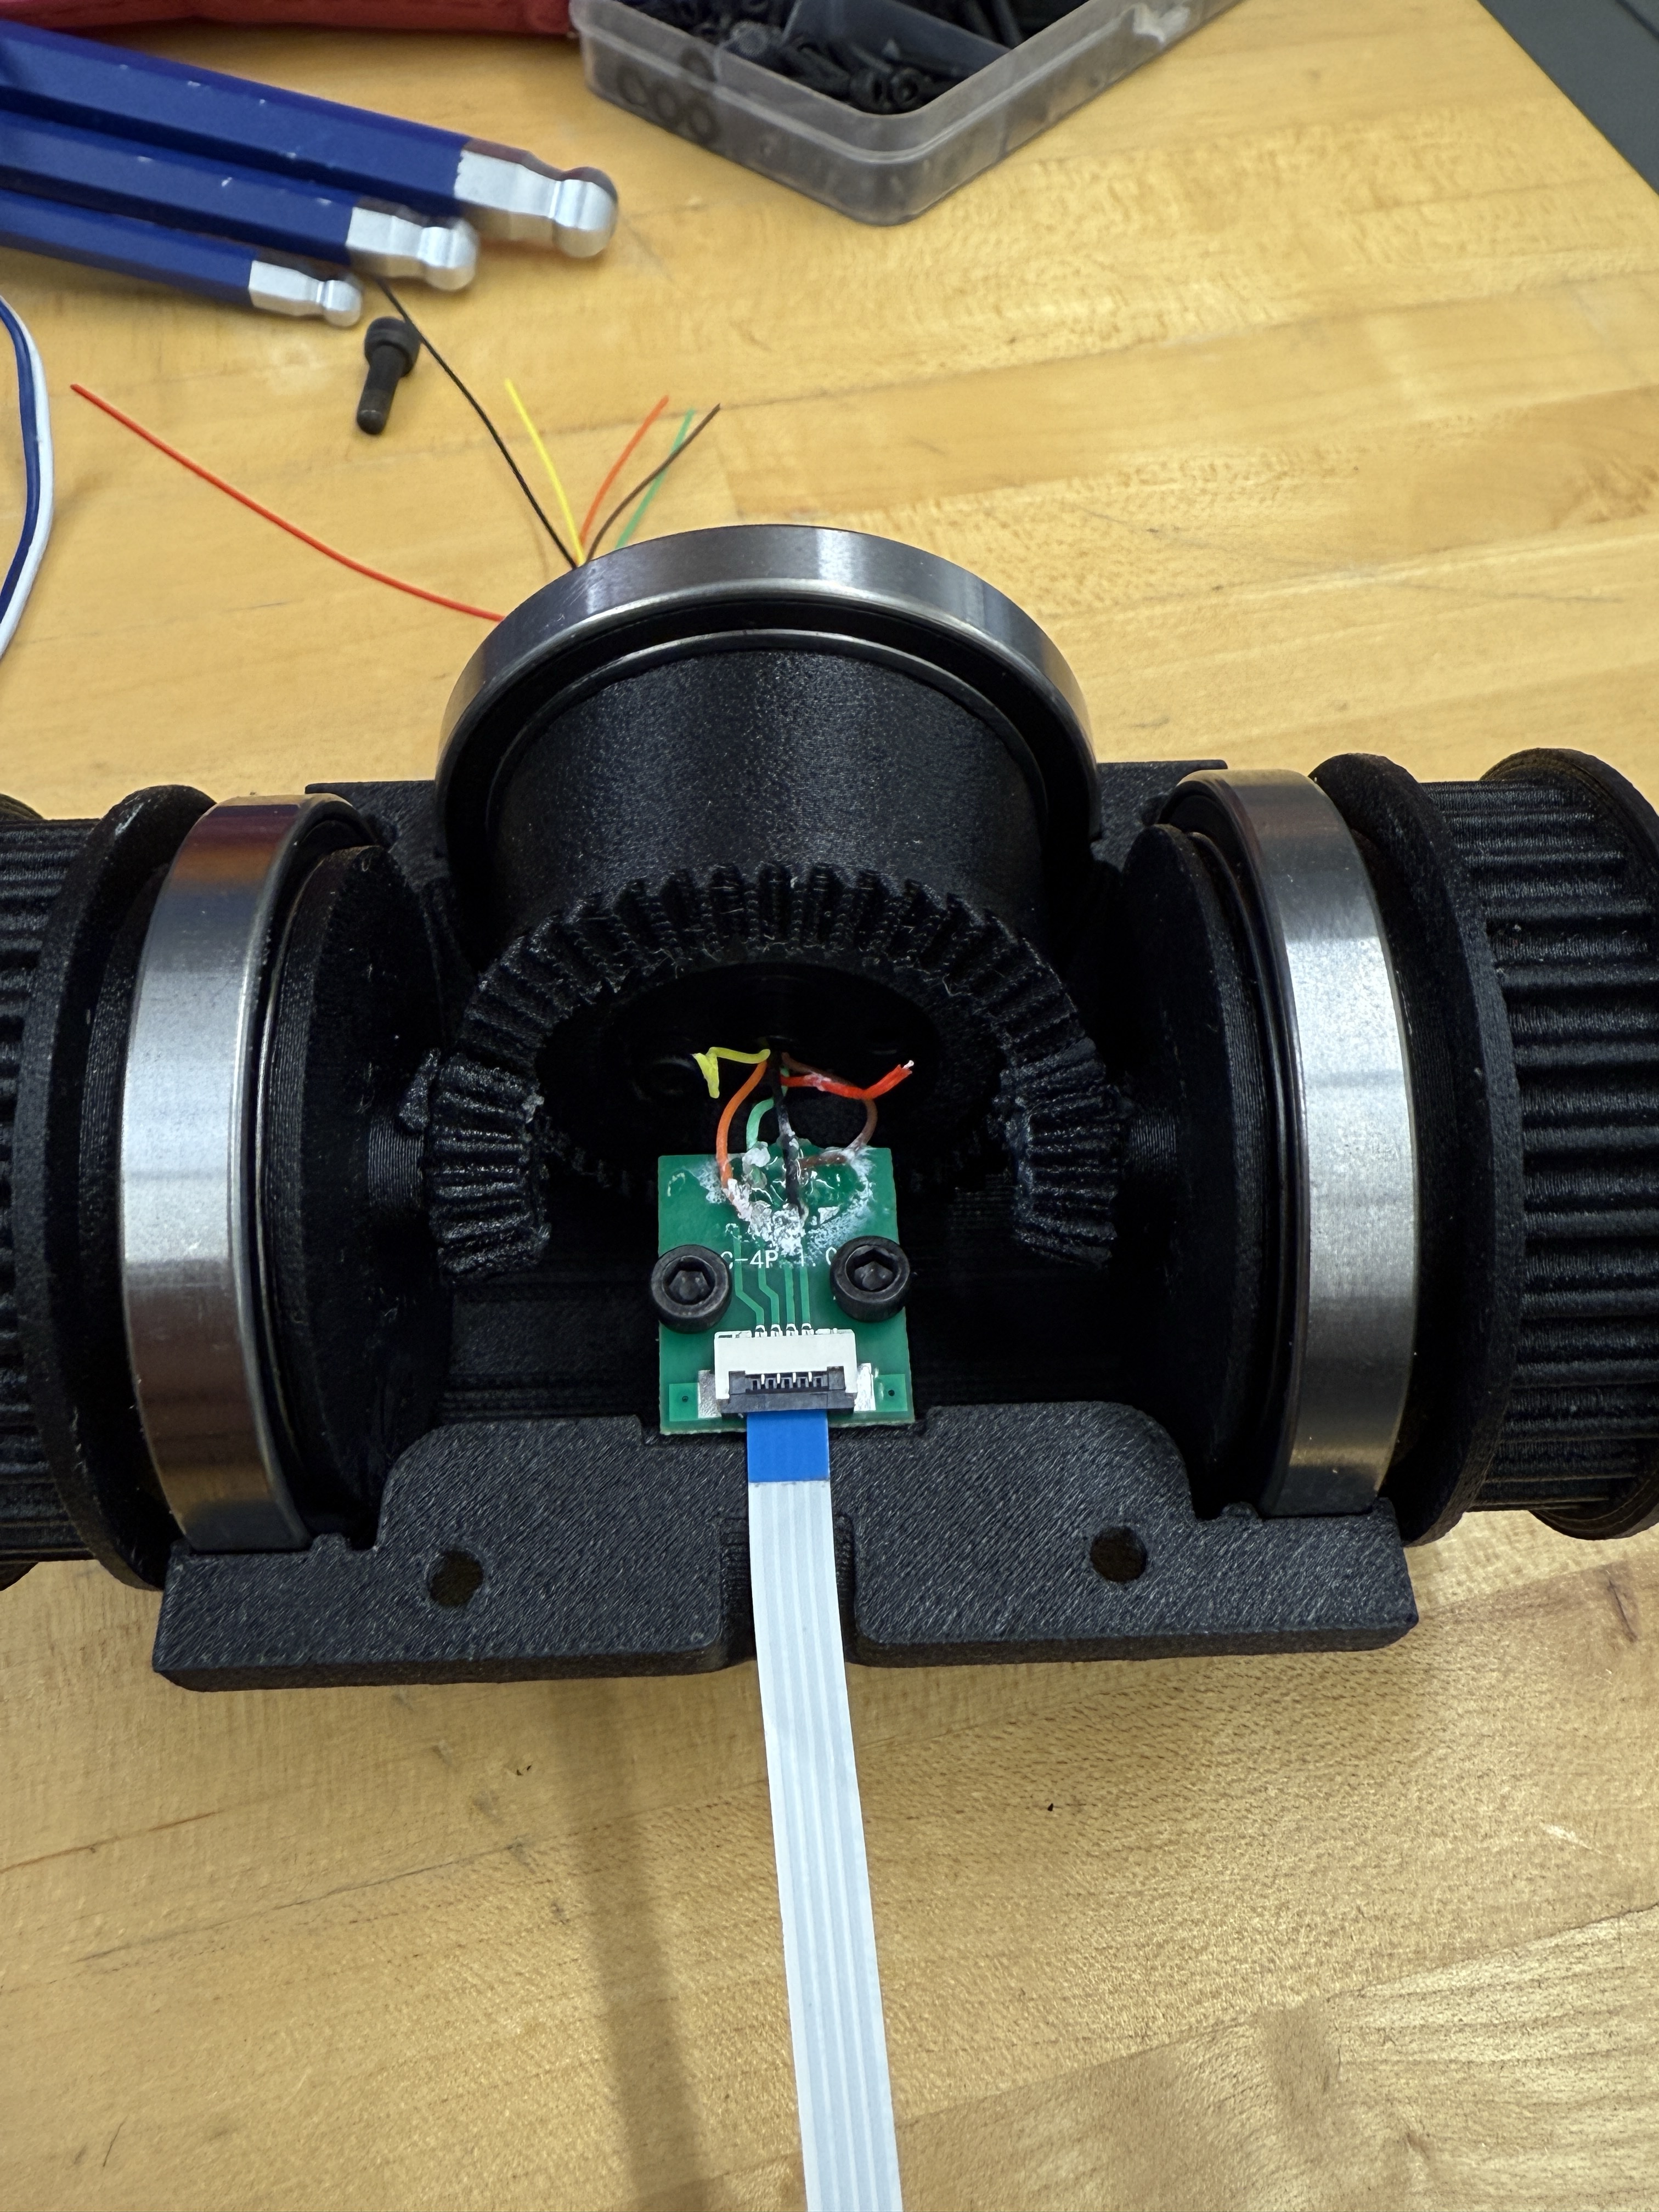
End-to-end tests documented in the April 2026 report confirmed PC-to-microcontroller communication, absolute servo position commands, and adjustable motion timing. The interface used POST requests for motion commands and GET requests for system status. The project videos and images show prototype testing and the developing mechanical assembly.
From Phase 1 to Phase 2
The April report proposed further mechanical assembly, multi-motor control, and safety integration. The September Phase 2 plan defines the next build as MASQ V1.0, a five-axis arm using CAN-based communication. Its assembly, calibration, and validation milestones are planned work; the results above describe the Phase 1 prototype.